MangoBot partner footage · short excerpt
01 / Education & visitor experiences
Learning through interaction
Make robotics something people can observe up close.
Explore the use case
Home / Robots / Education & Research
Humanoids, quadrupeds and dexterous robot hands for teaching and research, plus a quadruped teaching kit. Select the system around the learning objective.
Robots for this sector
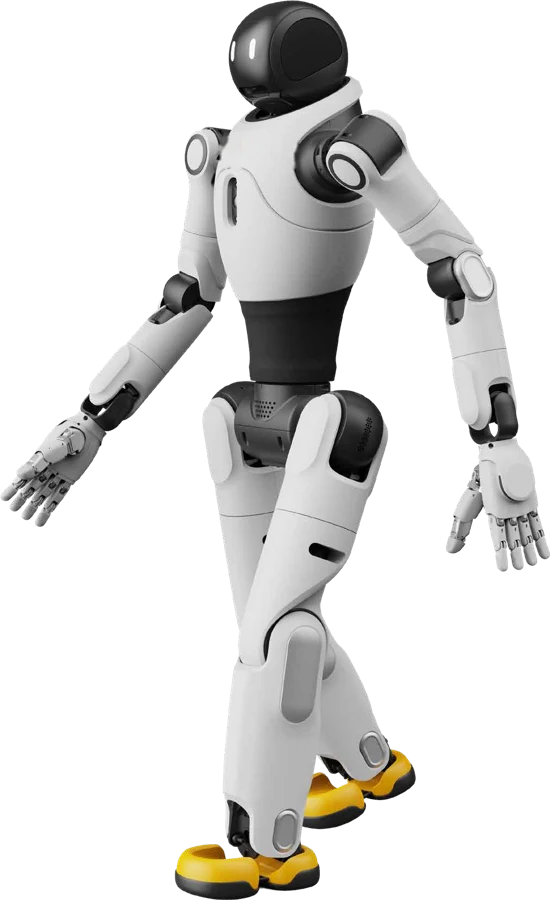 Compact humanoid
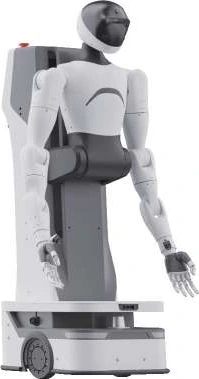 Research humanoid
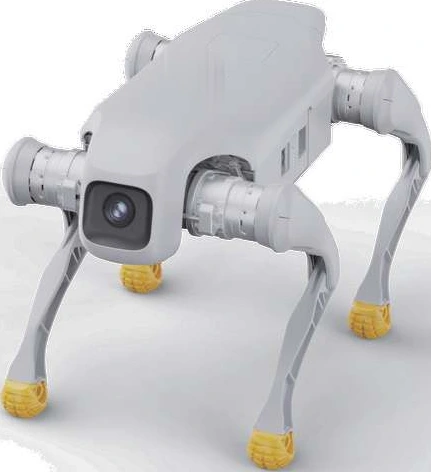 Teaching quadruped
 Dexterous robot hand
 Dexterous robot hand
Wheeled humanoid platform for embodied AI research and teaching. The portfolio describes a 275 TOPS computing platform, three depth cameras and five fisheye cameras, with datasets and a toolchain for training and testing models.
Applications: Embodied AI labs, imitation learning and university research.
Reference specifications: 130-180 cm height · 150 kg · 4 h+ battery life. 20+ degrees of freedom · 70 cm single arm span · 3 RGBD + 5 fisheye cameras.
Discuss this system ↗Compact quadruped for classrooms and research labs. Ethernet, USB, SBUS and UART ports support connecting additional hardware. The portfolio lists manuals, SDK, URDF models and Isaac/MuJoCo simulation.
Applications: Teaching, hardware integration and robotics research.
Reference specifications: 15 kg · up to 8 kg payload · 1-2 h battery life. 61 × 37 × 40.6 cm standing size · 3.7 m/s maximum speed · 30° maximum climbing angle in standard environment.
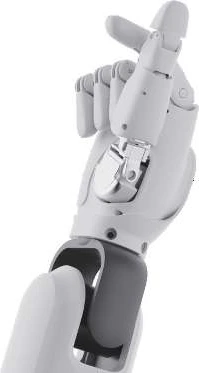
Discuss this system ↗Dexterous robot hand for labs working on grasping and manipulation. The portfolio lists a manual, SDK, finger-control API, URDF and MJCF models, plus Windows and Linux control software.
Applications: Grasping, finger control and manipulation research.
Reference specifications: 500 g · 5 N fingertip force · 0.5 mm repeatability. 10+6 degrees of freedom · 180 × 85 mm · 0.7 s open/close.
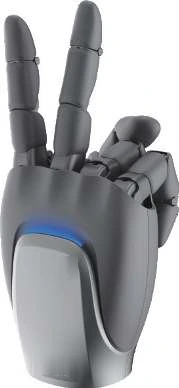
Discuss this system ↗Dexterous robot hand for grasping and manipulation research. The portfolio lists the same software and simulation resources as OmniHand, with different force, size and repeatability figures.
Applications: Grasping, finger control and manipulation research.
Reference specifications: 750 g · 20 N fingertip force · 0.4 mm repeatability. 12+7 degrees of freedom · 207 × 98 mm · 0.7 s open/close.
Discuss this system ↗A course and hardware package for universities, technical colleges and research labs. The portfolio describes 96 hours over two semesters, eight teaching-material categories in English and Chinese, 200+ video lessons and 300+ exercises.
Listed hardware includes a depth camera and LiDAR, voice module, 156 TOPS computing module, and open control and low-level interfaces. Confirm the exact kit, robot compatibility, software access and included teaching resources during scoping.
Discuss the teaching kit ↗Product descriptions and reference specifications are from the FRWRD Events & Education portfolio, which attributes them to manufacturer data. Figures are subject to change and confirmation. Availability, exact configuration, software access, training and support are agreed for the selected system and project.
From footage to a use case
01 / Education & visitor experiences
Make robotics something people can observe up close.
Explore the use casePartner demonstrations from MangoBot, not FRWRD deployments. Assessment is required for your site.
Other sectors
Hospitality, Events & Public Spaces ↗ Industrial & Infrastructure ↗
Begin with the learning objective: interaction, observation, embodied AI, mobility, grasping or manipulation. The education range includes the Compact Interactive Humanoid, G1, D1 Edu, OmniHand variants and a quadruped teaching kit.
Share the room layout, participants, intended activity and supervision arrangements. Do not assume a robot is suitable for an unsupervised classroom or every research task.
How we scope it
Buyer questions
Discuss a pilot around a defined task and assessment. Scope and commercial terms must be confirmed.
Support responsibilities, training and operation need to be agreed for the specific project. This page does not promise an included staffing package.
Compare the task, environment and relevant capabilities, then confirm fit with FRWRD. Bring the requirement, rather than booking from specifications alone.
FRWRD does not manufacture robots. We work with specialist manufacturers around the world and sit between them and GCC customers: identify the task, select the system, coordinate a pilot, support deployment and stay with it after handover.
It starts with the task, the work area, access and the existing workflow. What needs to change in the configuration or the way the team works depends on the system and the site, and is agreed as part of the pilot scope rather than assumed up front.
A pilot fits when the task is repeated, the result can be checked and you can say what a useful outcome looks like. Bring the task, the site, the access constraints and the output you need. We agree what to measure: quality of the result, fit with the workflow, operating time and the effort your team needs to run it. See robotics pilots.
Rental suits events, exhibitions, demonstrations and short-term applications. Purchase, rental and pilot terms differ by robot, so availability and the model that applies are confirmed for the system and project you ask about.
Start with the task
FRWRD Intelligence
Based in Abu Dhabi and Doha · Serving the GCC
Enquiries are read by the FRWRD team